Robots are moving beyond repetitive tasks in controlled environments into applications where they must navigate, manipulate, interact and adapt to changing conditions. As autonomy and Physical AI advance, robots need more than perception and positioning. They need physical awareness: an understanding of how they move, the forces and loads acting on them, and how they physically interact with people, objects and their environment.
Turning physical awareness into dependable robotic performance requires more than sensing alone. Embedded measurement provides the physical-state information needed for control, while engineering measurement and testing provide the evidence needed to understand and validate how the complete system behaves. Simulation, test and operational data can then be connected to assess performance, durability and reliability under representative real-world conditions.
HBK connects physical sensing, engineering measurement, test, data analysis, durability and reliability across the robotics lifecycle. This helps engineering teams understand real behaviour, validate systems against operating conditions and move from successful prototypes to dependable robotic systems.
Advanced robots demand more than sensors. They require a true engineering partner. From technology selection to co-engineering, HBK helps robotics OEMs reduce risk, accelerate development, and ensure consistent performance at scale.
Building a robot that works in a laboratory is only the beginning. Success requires validating real-world performance, ensuring durability, reducing failure risk, and scaling deployment with confidence. HBK uniquely combines physical sensing, data acquisition, testing, durability engineering, and reliability analysis to support every stage of the journey from concept to field operation.
Sensing must become part of the robotic architecture rather than an external addition. Mechanical envelope, stiffness, mass, cable routing, latency, communication interfaces, and environmental requirements can all influence measurement quality, control performance, and robot dynamics.
HBK bridges the gap between R&D test-bench measurements and embedded OEM sensor integration. We support force, torque, strain, load, multi-axis, and inertial measurement tailored for modern architectures. Custom sensing elements, electronics, firmware, and calibration are engineered around your mechanical constraints, enabling ultra-low latency and seamless integration with industrial networks such as EtherCAT, CAN bus, PROFINET, as well as ROS environments.
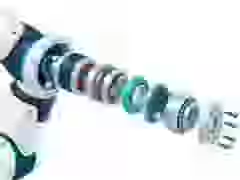
A working prototype must demonstrate more than functional motion. Engineers need to determine whether forces, joint loads, structural response, motion, and physical interactions align with expected behaviour across representative operating conditions.
Physical measurement provides the evidenceneeded to correlate models, identify unexpected loads, and characterise system behaviour. HBK’s measurement and test capabilities enable engineers to combine mechanical, force/torque, and inertial data to understand how the robot responds as an integrated system and identify design improvements earlier.
As robotic systems become more dynamic and interactive, control performance increasingly depends on accurate, low-latency physical-state information. Position alone cannot describe contact forces, external disturbances, payload effects, orientation changes, or multi-axis interaction.
Force/torque, joint torque, and inertial sensing provide complementary feedback for closed-loop control, manipulation, balance, and motion. Synchronised measurement enables engineers to correlate commands with physical response, validate control strategies, and quantify performance under representative operating conditions
Repeated motion, changing payloads, impacts, and variable duty cycles expose robots to complex load histories that are difficult to represent using simplified assumptions. At the same time, tightly integrated mechanical, electronic, and control systems can create interconnected failure modes.
Measured operating data can be combined with durability and reliability analysis to identify damaging events, predict fatigue life, and assess failure risk. HBK’s nCode and ReliaSoft capabilities extend physical validation into structural durability, FMEA, component reliability, and system-level analysis, helping teams address failure risks before they become costly field problems.
Once robots enter operation, real-world usage becomes an important source of engineering insight. Different tasks, environments, payloads, and duty cycles can create conditions that are difficult to reproduce during development.
Operational sensor and system data can reveal representative loads, usage profiles, damaging events, and reliability patterns. Feeding these insights back into engineering analysis helps teams refine validation profiles, improve maintenance strategies, and strengthen future designs.
As robots move into more dynamic and mission-critical environments, performance must remain predictable across changing loads, operating conditions and duty cycles. Explore how real-world measurement, durability engineering and reliability analysis help bridge the gap between successful prototypes and dependable deployment.
Industrial robots combine speed, precision, and repeatability with demanding duty cycles. Force and torque sensing, physical testing, and reliability engineering help teams validate robot interaction, understand repeated loading, and integrate components seamlessly with factory-floor fieldbuses such as PROFINET and EtherCAT.
Collaborative robots operate in shared environments where physical interaction, accurate force control, and predictable behaviour are essential. Compact force, torque, and 6DoF sensing can be combined with durability analysis to support consistent performance and human safety throughout the robot’s lifecycle.
AMRs and AGVs operate across changing routes, payloads, and environmental conditions. Inertial and load sensing, operational-data analysis, and fatigue prediction help teams understand motion, characterise real mission profiles, and assess long-term system performance.
Humanoid and legged robots require continuous awareness of motion, orientation, and load distribution. Combining inertial, force, and multi-axis sensing, alongside innovations such as contactless torque sensing, advanced thermal management, and extreme mass optimisation, supports dynamic balance and locomotion while meeting strict OEM packaging constraints.
Medical robotic systems require precise motion and interaction together with highly predictable performance. Compact force and torque sensing, custom joint measurement, FMEA, and reliability analysis support controlled physical interaction and the engineering of dependable, compliant systems.
Agricultural robots operate under harsh conditions, changing loads, varied terrain, and challenging environmental conditions. Rugged sensing, navigation technologies, operational data analysis, and reliability engineering help teams understand real operating behaviour and improve long-term field performance.
Autonomous robots need more than perception and position information. They must understand how they are moving, the loads acting on their structures and how they are physically interacting with objects, people and their environment. Force, torque, load and inertial measurements provide this physical-state information, supporting more informed control decisions and validation of real-world behaviour.
Position and vision indicate where a robot or object is, but they do not fully describe physical interaction. Force and torque sensing measure contact forces, resistance and applied loads directly, giving control systems additional information for manipulation, assembly and other tasks where physical interaction determines performance.
A 6DoF force/torque sensor measures three linear forces – Fx, Fy and Fz – and three moments – Mx, My and Mz. Together, these measurements describe the complete mechanical interaction at the measurement point, allowing robotic systems to quantify combined forces and torques rather than relying on single-axis information.
IMUs measure acceleration and angular rate and can support estimation of orientation and motion. Their data can be processed within fast control loops to help a robot understand its physical state. Combined with GNSS or other aiding sources, inertial sensing can also support position, velocity and navigation.
Balance depends on more than orientation alone. Combining inertial information with force, torque and load measurements provides insight into robot motion, external disturbances and load distribution. This gives engineers a more complete understanding of physical state for developing and validating stability and balance strategies.
Custom sensing becomes relevant when standard sensors cannot meet mechanical envelopes, stiffness, mass, overload, latency, environmental or interface requirements. Designing the sensing element, mechanics, electronics and calibration around the robot can improve integration while preserving the measurement and dynamic performance required by the system.
Measured force, torque, strain and operational data can be transformed into representative load cases and combined with fatigue analysis. This allows engineers to identify damaging events and structural hotspots and predict fatigue life using operating conditions that better represent how the robot will be used.
Reliability can be addressed from early development through FMEA, component reliability prediction, system reliability modelling and durability analysis. Connecting these methods with simulation, prototype measurements, test data and operational data enables teams to identify failure risks earlier and continuously validate reliability throughout development.
This will bring together HBM, Brüel & Kjær, nCode, ReliaSoft, MicroStrain and Discom brands, helping you innovate faster for a cleaner, healthier, and more productive world.